A driving world model
WAM-Sim
World Anchored Memory Meets Online RL
for Consistent and Realistic Driving Simulation
Fudan UniversityYinwang Intelligent Technology Co., Ltd
World-anchored memory
Real-world scene consistency
Generated scenes stay close to the real-world reference.
World-anchored memory
Persistent object identity
Vehicles keep a consistent appearance when they come back into view.
Minute-level generation
Long-horizon generation
Each clip is a continuous minute-level rollout.
Beyond consistency
Realistic traffic participants
Pedestrians, riders and vehicles with natural motion.
Generalization
Diverse environments and scenes
Across weather, lighting, and road conditions.
Diverse environments
Diverse scenes
Quantitative results
nuScenes
| Method | Synthesis Resolution | Fidelity | 3D Detection | BEV Seg mIoU | |||
|---|---|---|---|---|---|---|---|
| FVD ↓ | FID ↓ | mAP ↑ | NDS ↑ | Road ↑ | Vehicle ↑ | ||
| Ori nuScenes | 900 × 1600 | - | - | 35.54 | 41.21 | 73.66 | 34.82 |
| (I) Image Generation Methods | |||||||
| BEVControl | 224 × 400 | - | 24.85 | - | - | 60.80 | 26.80 |
| PerLDiff | 256 × 384 | - | 13.36 | 15.24 | 24.05 | 61.26 | 27.13 |
| DrivePTS | 224 × 480 | - | 11.45 | 15.37 | 25.49 | 63.95 | 27.82 |
| MagicDrive | 224 × 400 | - | 16.20 | 12.30 | 23.32 | 61.05 | 27.01 |
| (II) Video Generation Methods | |||||||
| DriveDreamer | 256 × 448 | 452.0 | 26.80 | - | - | - | - |
| DriveDreamer-2 | 256 × 448 | 105.10 | 25.00 | - | - | - | - |
| DrivingDiffusion | 512 × 512 | 332.0 | 15.83 | - | 33.10 | 63.20 | 31.60 |
| Panacea | 256 × 512 | 139.0 | 16.96 | 11.58 | 22.31 | 55.78 | 22.74 |
| DreamForge | 224 × 400 | 224.8 | 14.61 | 13.01 | 22.16 | 65.27 | 28.36 |
| MagicDrive-V2 | 848 × 1600 | 94.84 | 20.91 | 17.65 | - | 59.79 | 32.73 |
| Ours | 704 × 1280 | 25.72 | 3.47 | 24.16 | 32.10 | 71.23 | 32.97 |
Self-Collected Dataset
| Method | Visual Fidelity | VBench Metrics | Persistence | Object & Physics | |||||
|---|---|---|---|---|---|---|---|---|---|
| FID ↓ | FVD ↓ | Quality ↑ | Subject ↑ | Background ↑ | Sub. Coh. ↑ | Scene Sim. ↑ | Sub. Fid. ↑ | Phys. Plaus. ↑ | |
| (I) Inference Only | |||||||||
| UniMLVG | 44.21 | 753.16 | 75.75 | 83.43 | 89.77 | 0.591 | 0.708 | 39.19 | 46.57 |
| OpenDWM | 37.69 | 535.42 | 76.54 | 82.36 | 90.11 | 0.532 | 0.731 | 37.24 | 47.44 |
| HorizonDrive | 24.86 | 218.51 | 78.41 | 84.55 | 88.09 | 0.553 | 0.804 | 42.98 | 51.19 |
| (II) SFT on Self-Collected Data | |||||||||
| OmniDreams | 11.58 | 81.64 | 77.63 | 86.17 | 92.35 | 0.646 | 0.863 | 37.64 | 47.99 |
| Ours | 10.95 | 74.20 | 78.71 | 86.98 | 92.54 | 0.681 | 0.910 | 44.00 | 55.96 |
Method
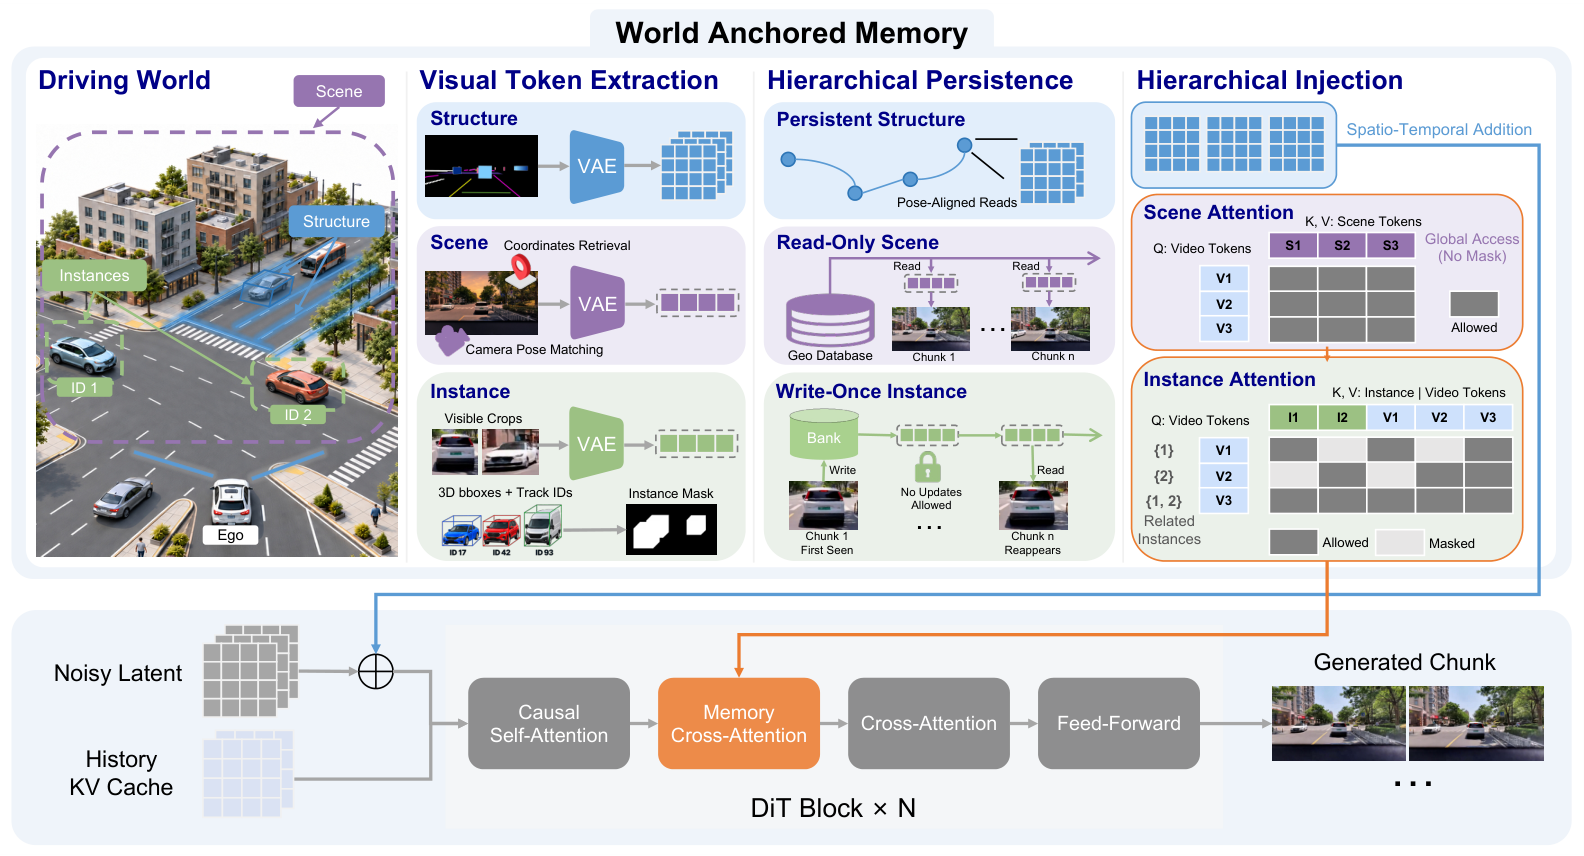
Persistent world memory meets online reinforcement learning.
Persistent geometry
Pose-aligned HD-map tokens anchor the road layout.
Read-only appearance
Geolocated background tokens supply consistent scene context.
Write-once identity
Track-keyed tokens preserve individual traffic participants.
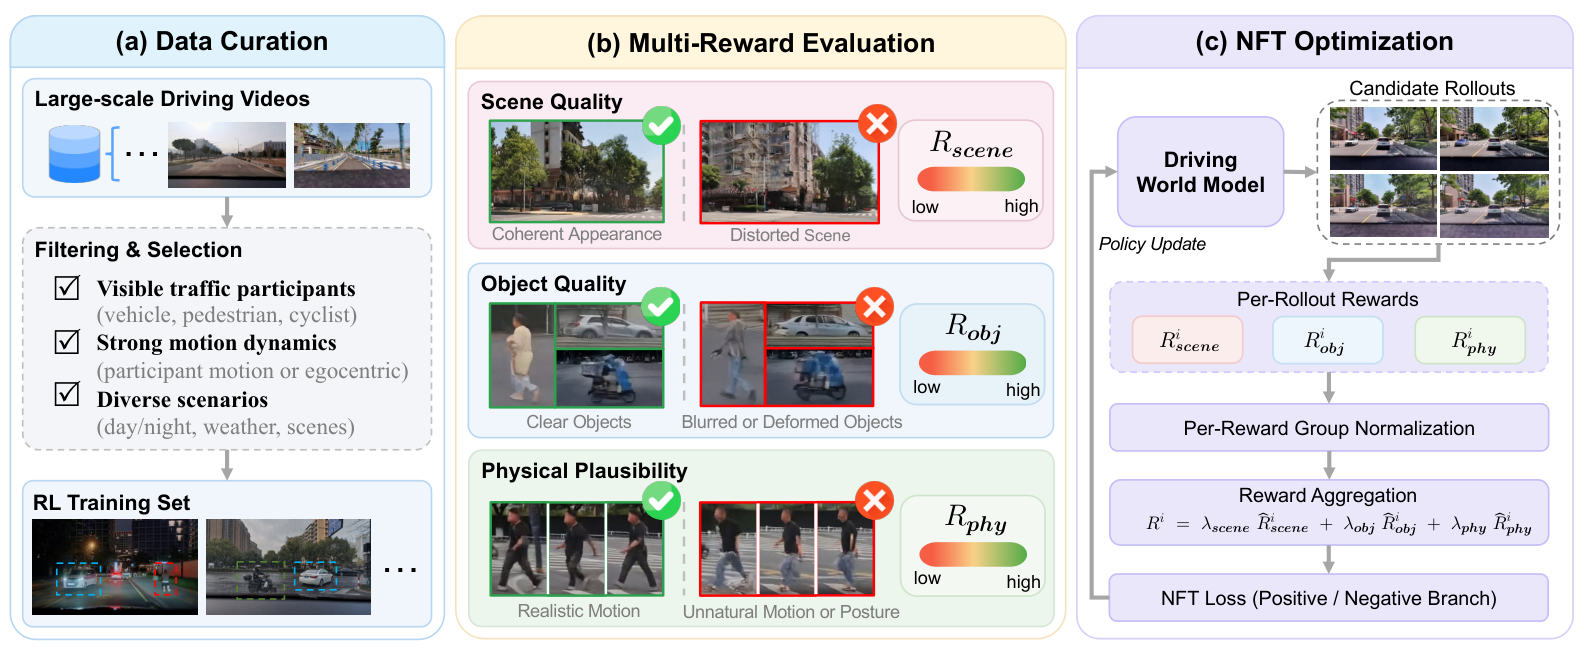
Drive DiffusionNFT
Self-generated candidate rollouts receive rewards for scene quality, object quality, and physical plausibility. Group-wise reward normalization and flow-matching policy optimization refine the generator while the persistent memory anchors the world.